Policy routing
I build systems that choose the best controller at each step, instead of asking one robot policy to solve every part of a task.
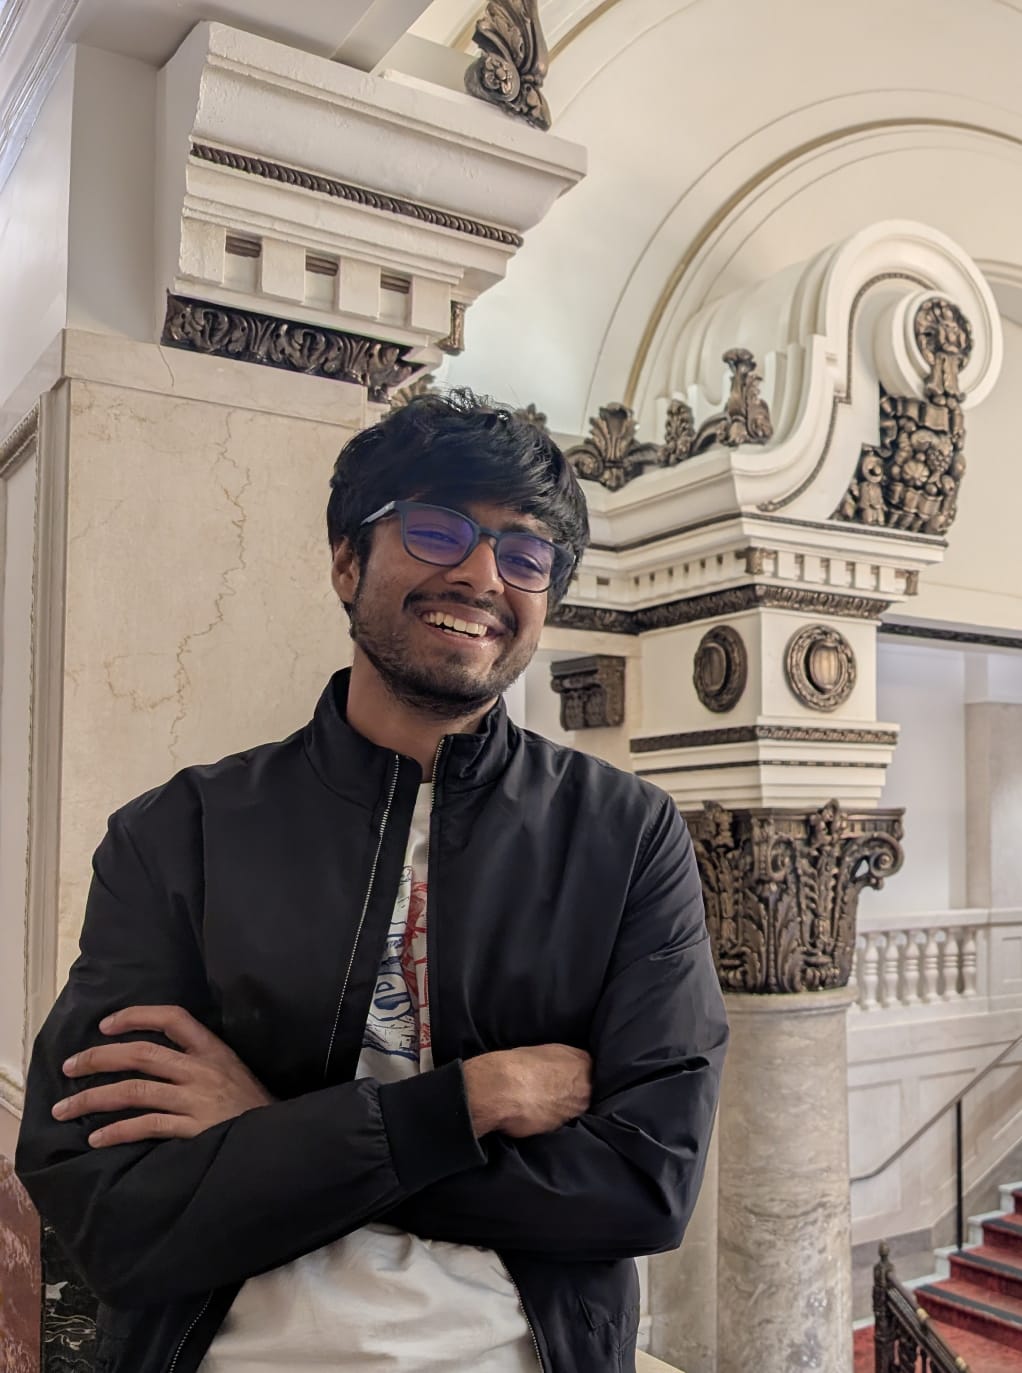
M.S. Computer Science (AI) · University of Southern California
I am an embodied AI researcher at USC working on policy routing, robust robot evaluation, and learning from limited data. I build systems that turn ambitious ideas into robots that work beyond the lab.
I currently work with Jesse Thomason in USC’s GLAMOR Lab and Erdem Bıyık in the LIRA Lab. My work brings together offline reinforcement learning, vision-language-action models, and robust perception for real-world robotics.
I work on the gap between a capable model and a dependable system. My research asks how robots can select the right behavior, recognize when they are likely to fail, and generalize when the world looks different from training data.
I build systems that choose the best controller at each step, instead of asking one robot policy to solve every part of a task.
I study how generalist robot models can connect language and visual perception to reliable, grounded action.
I develop failure detectors and safety probes that identify when a robot’s view, instruction, or environment has shifted.
I use targeted contrast sets and simulation data to test what actually transfers before a model reaches a real robot.
Joined USC’s LIRA Lab to work on data-efficient learning and social attention for trajectory forecasting.
Joined USC’s GLAMOR Lab, where I work on policy routing and robust evaluation for language-guided robots.
Submitted SWAP and SAFECAST to CoRL 2026, advancing policy routing and robust failure detection for vision-language-action models.
A few systems I have helped take from research questions to measurable outcomes.
Robot learning · Offline RL
No single robot policy excels at every part of a task. SWAP learns to choose among VLA and control policies at each decision step, turning policy selection into an offline reinforcement learning problem.
Up to 33% higher real-world task success and 28.3% shorter successful trajectories.
Robustness · VLA evaluation
SAFECAST uses contrast-set perturbations and conformal prediction to detect when a robot policy is likely to fail under visual, environmental, or instruction changes.
Designed to make deployment-time failures visible before they become costly rollouts.
Generative AI · Computer vision
At PixelBin, I helped build an enterprise image-generation system using apparel segmentation, Flux Fill LoRA, and ControlNet for controllable synthetic model imagery.
Reduced physical model-generation overhead by 40% and supported production-scale image workflows.
NLP · Socio-technical systems
I developed an end-to-end pipeline that collected over 10,000 Hyperloop discussions, modeled public concerns, and connected language signals to transport-economics simulations.
Led to multiple publications and helped support a second-place finish at European Hyperloop Week 2024.
Selected academic work across robot learning, multimodal AI, and socio-technical systems.
Aditeya Prajapati, Jesse Thomason · Target: CVPR 2026
Visual appearance and motion each miss part of a signed utterance. We combine pose dynamics with self-supervised visual features to learn a stronger representation for isolated sign recognition.
Mousumi Das, Aditeya Prajapati, Abrar Anwar, Jesse Thomason · CoRL 2026
Rather than committing to one controller for an entire rollout, SWAP learns an offline-RL critic that routes each step to the most suitable VLA or keypoint-based policy. It improves real-robot task success by up to 33%.
H. B. Rajaprakash, Aditeya Prajapati, R. Xue, Abrar Anwar, Jesse Thomason · CoRL 2026
SAFECAST probes hidden representations for failure signals under deployment-time distribution shifts. Contrast-set training and conformal calibration make those signals more robust across visual, environmental, and linguistic variation.
K. Pandit, Aditeya Prajapati, S. Jain, S. Fernandes, A. R. Shandliya, M. Saeed · HAICON 2026
We map recurring public concerns around Hyperloop using a curated social-media corpus, topic modeling, and sentiment analysis to connect technical proposals with the questions people actually raise.
K. Pandit, S. Jain, P. Sharma, Aditeya Prajapati, U. Chaurasiya, M. Saeed · HAICON 2026
This work models when replies diverge sharply from an original Hyperloop post, pairing semantic features with engagement signals to identify patterns of opinion inversion in public discussion.
A. R. Shandilya, V. Dongre, Aditeya Prajapati, et al. · SN Computer Science, 2026
We examine how 5G and Wi-Fi 6 can be combined into a resilient communications design for high-speed Hyperloop environments, where coverage, handoffs, and reliability become tightly coupled.
Aditeya Prajapati, S. Uchil, V. Patwa, N. Kapadia, R. G. Mehta · CRC Press, Taylor & Francis Group
A case study on applying machine learning to smart-bin waste prediction, framed around practical IIoT deployment choices and responsible technology considerations.
K. M. Dr. Bhushankumar Nemade, Somil Doshi, Preet Desai, Aditeya Prajapati, et al. · Rivista Italiana di Filosofia Analitica Junior, 2023
Developing SWAP, an offline-RL policy router that switches among VLA and control policies during robot manipulation. I built evaluation infrastructure spanning Libero simulation, DROID tasks, and a Franka Panda deployment, making it possible to compare heterogeneous policies under the same task conditions. The resulting system improved real-world success by up to 33% and shortened successful trajectories by 28.3%.
Exploring LLM-regularized social attention for trajectory forecasting. I distill offline LLM estimates of agent influence into a learned attention prior, so the model gains social context without an inference-time language-model cost. The approach reduces displacement error by 7% in low-data Argoverse 2 settings and aligns attention more closely with interaction-critical agents.
Built generative-AI image systems and production computer-vision services for retail imagery. My work combined apparel segmentation, Flux Fill LoRA, and ControlNet to enable controllable synthetic model generation, then supported the surrounding GCP pipeline from local Flask testing through deployment. The team processed more than one million images and reduced physical model-generation overhead by 40%.
Worked with more than 500 GB of high-frequency telemetry from 15-plus offshore nodes at the KG D6 facility. I developed LSTM forecasting models that reduced regional-sales RMSE by 14.8%, and built an internal TensorFlow and TextBlob assistant trained on 10,000 operational FAQs to help automate recurring support requests.
M.S. in Computer Science (Artificial Intelligence)
Jan 2026 to Dec 2027 · Los Angeles, CAB.Tech in Information Technology
Aug 2020 to May 2024 · Mumbai, IndiaML: PyTorch, TensorFlow, Hugging Face, scikit-learn, CUDA
Robotics: Offline RL, OpenVLA, Libero, DROID, Franka Control Interface
Systems: Python, C++, SQL, GCP, Docker, Kubernetes, SLURM
I care about technology that is useful outside a demo: systems that people can understand, trust, and build on. My path from Mumbai to Los Angeles has taken me through computer vision, language, large-scale data, and robotics, and I enjoy the process of connecting ideas across those areas.
Outside the lab, I love sports and have played volleyball at the state level. It has taught me the same things I value in research: preparation, communication, adapting under pressure, and showing up for the team.
Currently seeking research internships, research collaborations, and machine learning roles.